温湿度检测和液位测量
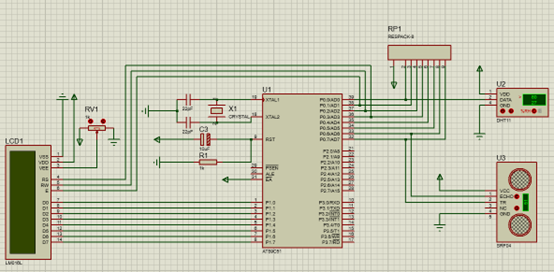
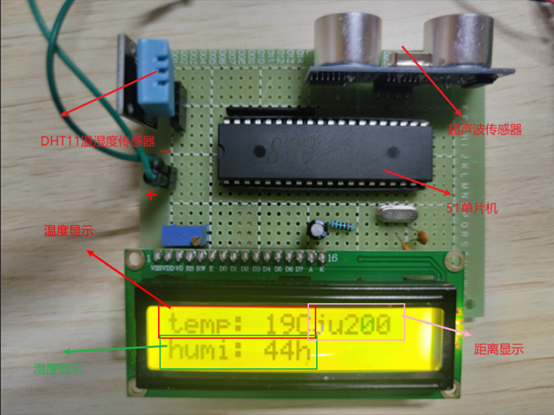
实现思路: DHT11温湿度传感器和超声波传感器测量数据, 通过at89c51单片机数据处理, 最后将数据显示在液晶显示屏1602上
逻辑图

传感器特点
DHT11 温湿度传感器
简介
DHT11是一款有已校准数字信号输出的温湿度传感器。 其精度湿度±5%RH, 温度±2℃,量程湿度5~95%RH, 温度-20~+60℃。 DHT11 数字温湿度传感器 是一款含有已校准数字信号输出的温湿度复合传感器 ,它应用专用的数字模块采集技术和温湿度传感技术,确保产品具有极高的可靠性和卓越的长期稳定性。
Hc_Sr04 超声波传感器
简介
HC-SR04超声波测距模块可提供2cm-400cm的非接触式距离感测功能,测距精度可达高到3mm;模块包括超声波发射器、接收器和控制电路。其基本工作原理采用IO口TRIG触发测距,给至少10us的高电平信号;模块自动发送8个40khz的方波,自动检测是否有信号返回;有信号返回,通过IO口ECHO输出一个高电平,高电平持续的时间就是超声波从发射到返回的时间。
设计原理图
实物展示
程序代码
1. 液晶显示屏 1602
#include "reg51.h"
#include "string.h"
#include "stdio.h"
#include "dht11.h"
#include "delayms.h"
#include "CSBofCM.h"

#define uint unsigned int
#define uchar unsigned char

sbit scr_E = P0^1;
sbit scr_RW = P0^2;
sbit src_RS = P0^3;

uchar index;

int pre_temp, temp_suf, pre_humi, humi_suf;


// 定义温湿度显示数组
uchar temp[14] = "temp: ";
uchar humi[9] = "humi: ";


void write_address(uchar address)
{
    src_RS = 0;
    P1 = address;
    delayms(5);
    scr_E = 1;
    delayms(5);
    scr_E = 0;
}

void write_data(uchar data_)
{
    src_RS = 1;
    P1 = data_;
    delayms(5);
    scr_E = 1;
    delayms(5);
    scr_E = 0;
}

void lcd_init()
{
    scr_E = 0;
    scr_RW = 0;
    write_address(0x38);
    write_address(0x0c);
    delayms(50);
    write_address(0x06);
    delayms(50);
    write_address(0x01);
    delayms(50);
}

void display()
	{
    pre_temp = high_temp / 10;
    temp_suf = high_temp % 10;
    temp[6] = '0' + pre_temp;
    temp[7] = '0' + temp_suf;
    temp[8] = 'C';
    temp[9] = ' ';
    temp[9] = 'j';
    temp[10] = 'u';
    temp[11] = '0' + f1;
    temp[12] = '0' + f2;
    temp[13] = '0' + f3;

    // 在第一行写入温度
    write_address(0x80);
    for(index = 0;index < 14;index++)
    {
        write_data(temp[index]);
        delayms(5);
    }

    pre_humi = high_humi / 10;
    humi_suf = high_humi % 10;
    humi[6] = '0' + pre_humi;
    humi[7] = '0' + humi_suf;
    humi[8] = 'h';

    // 在第二行写入湿度
    write_address(0x80+0x40);
    for(index = 0;index < 9;index++)
    {
        write_data(humi[index]);
        delayms(5);
    }
}
 c++
2. 超声波传感器 Hc_Sr04
#include<reg51.h>
#include "intrins.h"


typedef unsigned int uint;
typedef unsigned char uchar;

sbit Echo=P0^6; //接受端
sbit Trig=P0^7; //控制端
uchar flag; //中断溢出标志


void CSB_Time0() interrupt 1 //T0中断用来计数器溢出,超过测距范围
{
    flag=1;
}

void Delay20us()
{
    unsigned char i;
    _nop_();
    i = 7;
    while (--i);
}

void CSB_Rstart() //启动模块
{
    Trig = 1;
    Delay20us();
    Trig = 0;
    return;
}

void CSB_Init()  // 初始化
{
    TMOD = 0x01;
    TH0 = 0;
    TL0 = 0;
    EA = 1;
    ET0 = 1;
}

uchar f1, f2, f3;
uint time;
float distance;
void CSB_GetOnce() //得到一次超声波测距模块的距离
{
    CSB_Rstart();
    while(!Echo); //当Echo为零时等待
    TR0 = 1; //开启计数
    while(Echo); //当Echo为1计数并等待
    TR0 = 0; //关闭计数
    time = TH0*256+TL0; //得到总时间,单位us
    distance = (float)(time*0.017);
    TH0 = 0;
    TL0 = 0; //清空定时器
    if((distance >=300)||flag==1) //超出测量范围显示 " X "
    {
        flag=0; //清空中断溢出标志
        f1 = 'X';
        f2 = ' ';
        f3 = ' ';
    }
    else
    {
        f1 = (uint)distance/100; //百位
        f2 = (uint)distance/10%10; //十位
        f3 = (uint)distance%10; //个位
    }
}
 c++
3. 温度传感器 DHT11
#include "reg51.h"
#include "intrins.h"

typedef unsigned char uchar;
typedef unsigned int uint;


//定义信号端口
sbit sign = P0^0;

void delay_us(char n)
{
    while(--n);
}

void delay_ms(int z)
{
    uchar x, y;

    while(z>=0)
    {
        _nop_();  //产生一条NOP指令 (起延时作用)
        x = 2;
        y = 199;
        do
        {
            while (--y);
        } while (--x);
        z--;
    }
}

void start()
{
    sign = 1;
    delay_us(2);
    sign = 0;
    delay_ms(20);
    sign = 1;
    delay_us(30);
}

uchar rec_one_byte()      //接收一个字节数据
{
    uchar i,dat = 0;
    for(i = 0;i < 8;i++)
    {
        while(!sign);

        delay_us(8);
        dat <<= 1; // 移位
        if(sign == 1)
            dat += 1;
        while(sign);
    }
    return dat;
}

uchar high_temp, low_temp, high_humi, low_humi, correct;

void receive_all_data()      //接收40位的数据
{
    start();
    if(sign == 0)
    {
        while(sign == 0);
        delay_us(40);
        high_humi = rec_one_byte();
        low_humi = rec_one_byte();
        high_temp = rec_one_byte();
        low_temp = rec_one_byte();
        correct = rec_one_byte();

        delay_us(25);
    }
}
 c++
4. 主函数
#include "reg51.h"
#include "1602.h"
#include "dht11.h"
#include "CSBofCM.h"

void main()
{
    lcd_init();
    CSB_Init();
    while(1)
    {
        receive_all_data();
        CSB_GetOnce();
        display();
    }
}
 c++